close menu
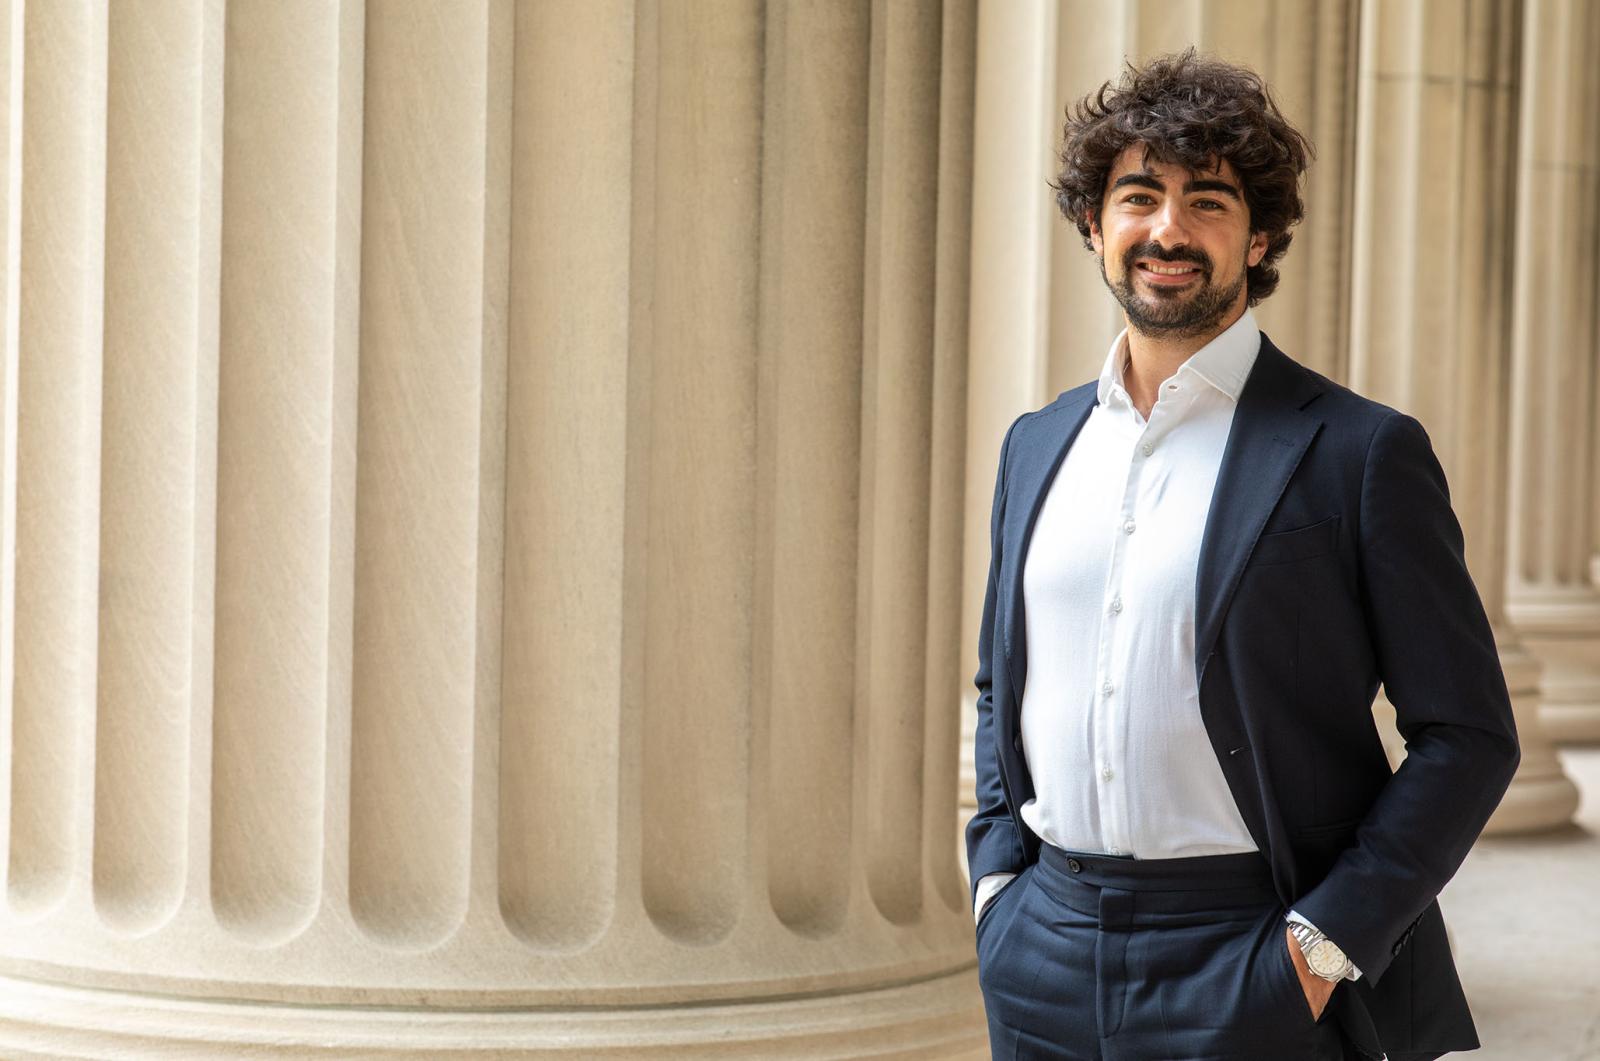
Federico Tessari
- Assistant Professor (Starting January 2027)
Interests
- Robotics for Human Mobility
- Human Neuromotor Control & Biomechanics
- Assistive and Rehabilitative Technologies
Faculty Details
Education
-
2014
Università degli Studi di Roma Tre
BSc -
2016
Politecnico di Torino
MSc -
2021
Politecnico di Torino & Italian Institute of Technology
PhD
Research Interests
- Robotics for Human Mobility
- Human Neuromotor Control & Biomechanics
- Assistive and Rehabilitative Technologies
Honors + Awards
- Best Paper Award, IEEE International Conference on Cyborgs and Bionic Systems (CBS) — Sep 2026
- Shortlisted Finalist, Falling Walls Foundation, Life Science Breakthroughs 2026 — July 2026
- Best Paper Award, IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) — Oct 2024
- Trainee Professional Development Award (TPDA), Society for Neuroscience (SfN) — Oct 2024
Publications
- Tessari, F., Hogan, N., (2026), Stabilizing stiffness is the most limiting factor in human force exertion, Nature Communications, https://doi.org/10.1038/s41467-026-74354-9
- Tessari, F., West, A.M., Hogan, N., (2025), Explaining human motor coordination via the synergy expansion hypothesis, Proc. Natl. Acad. Sci. U.S.A. 122 (13), https://doi.org/10.1073/pnas.2501705122
- Tessari, F., Hermus, J., Sugimoto-Dimitrova, R., Hogan N. (2024), Brownian processes in human motor control support descending neural velocity commands, Scientific Reports, Volume 14, https://doi.org/10.1038/s41598-024-58380-5
- Tessari F., R. Galluzzi, A. Tonoli, N. Amati, L. De Michieli, M. Laffranchi (2023), Knee prosthesis powered by a fully integrated and highly back-drivable electro-hydrostatic actuator, Mechatronics, Volume 91, 102972, ISSN 0957-4158, https://doi.org/10.1016/j.mechatronics.2023.102972
- Tessari, F., Galluzzi, R., and Amati, N. (2020). Efficiency-Driven Design Methodology of Gerotor Hydraulic Units. ASME. J. Mech. Des. doi: https://doi.org/10.1115/1.4045421